Inverse Kinematics Robotic Arm
A fully working pick-and-drop simulation built from fundamentals in MuJoCo and Python. Based on Jacobian calculation, damped least squares, and IK tuning.
View projectEngineer — San Francisco, CA
Back-end engineer with 5+ years at Microsoft and Kwartile. Now pursuing robotics, real-time sensing, and human-centered systems.
View Selected Work
I'm a back-end engineer with 5+ years building scalable, cloud-native systems. From real-time data pipelines at Microsoft to ML-driven platforms at early-stage startups.
After earning a Computer Science degree from UC Davis, I joined a startup where I built an entity resolution model with 97% accuracy, spun up real-time streaming infrastructure, and engineered a data platform from concept to production. Then I scaled up at Microsoft, working on critical tasks like reducing API latency by 59% and automating 80% of onboarding workflows.
I took a deliberate sabbatical in 2024 to redirect. I discovered a home for my skills in robotics, started teaching myself ROS2, building with simulation tools, participating in a hackathon, and built my own arm end-to-end. Now, I am actively looking for projects where my industry skills in Software Engineering can be useful to the Robotics space.
A fully working pick-and-drop simulation built from fundamentals in MuJoCo and Python. Based on Jacobian calculation, damped least squares, and IK tuning.
View projectA physical robot designed from scratch to respond to human interaction: rolling dice on command. Built to learn the fundamentals of ROS2, Gazebo, and RViz through hands-on construction.
View project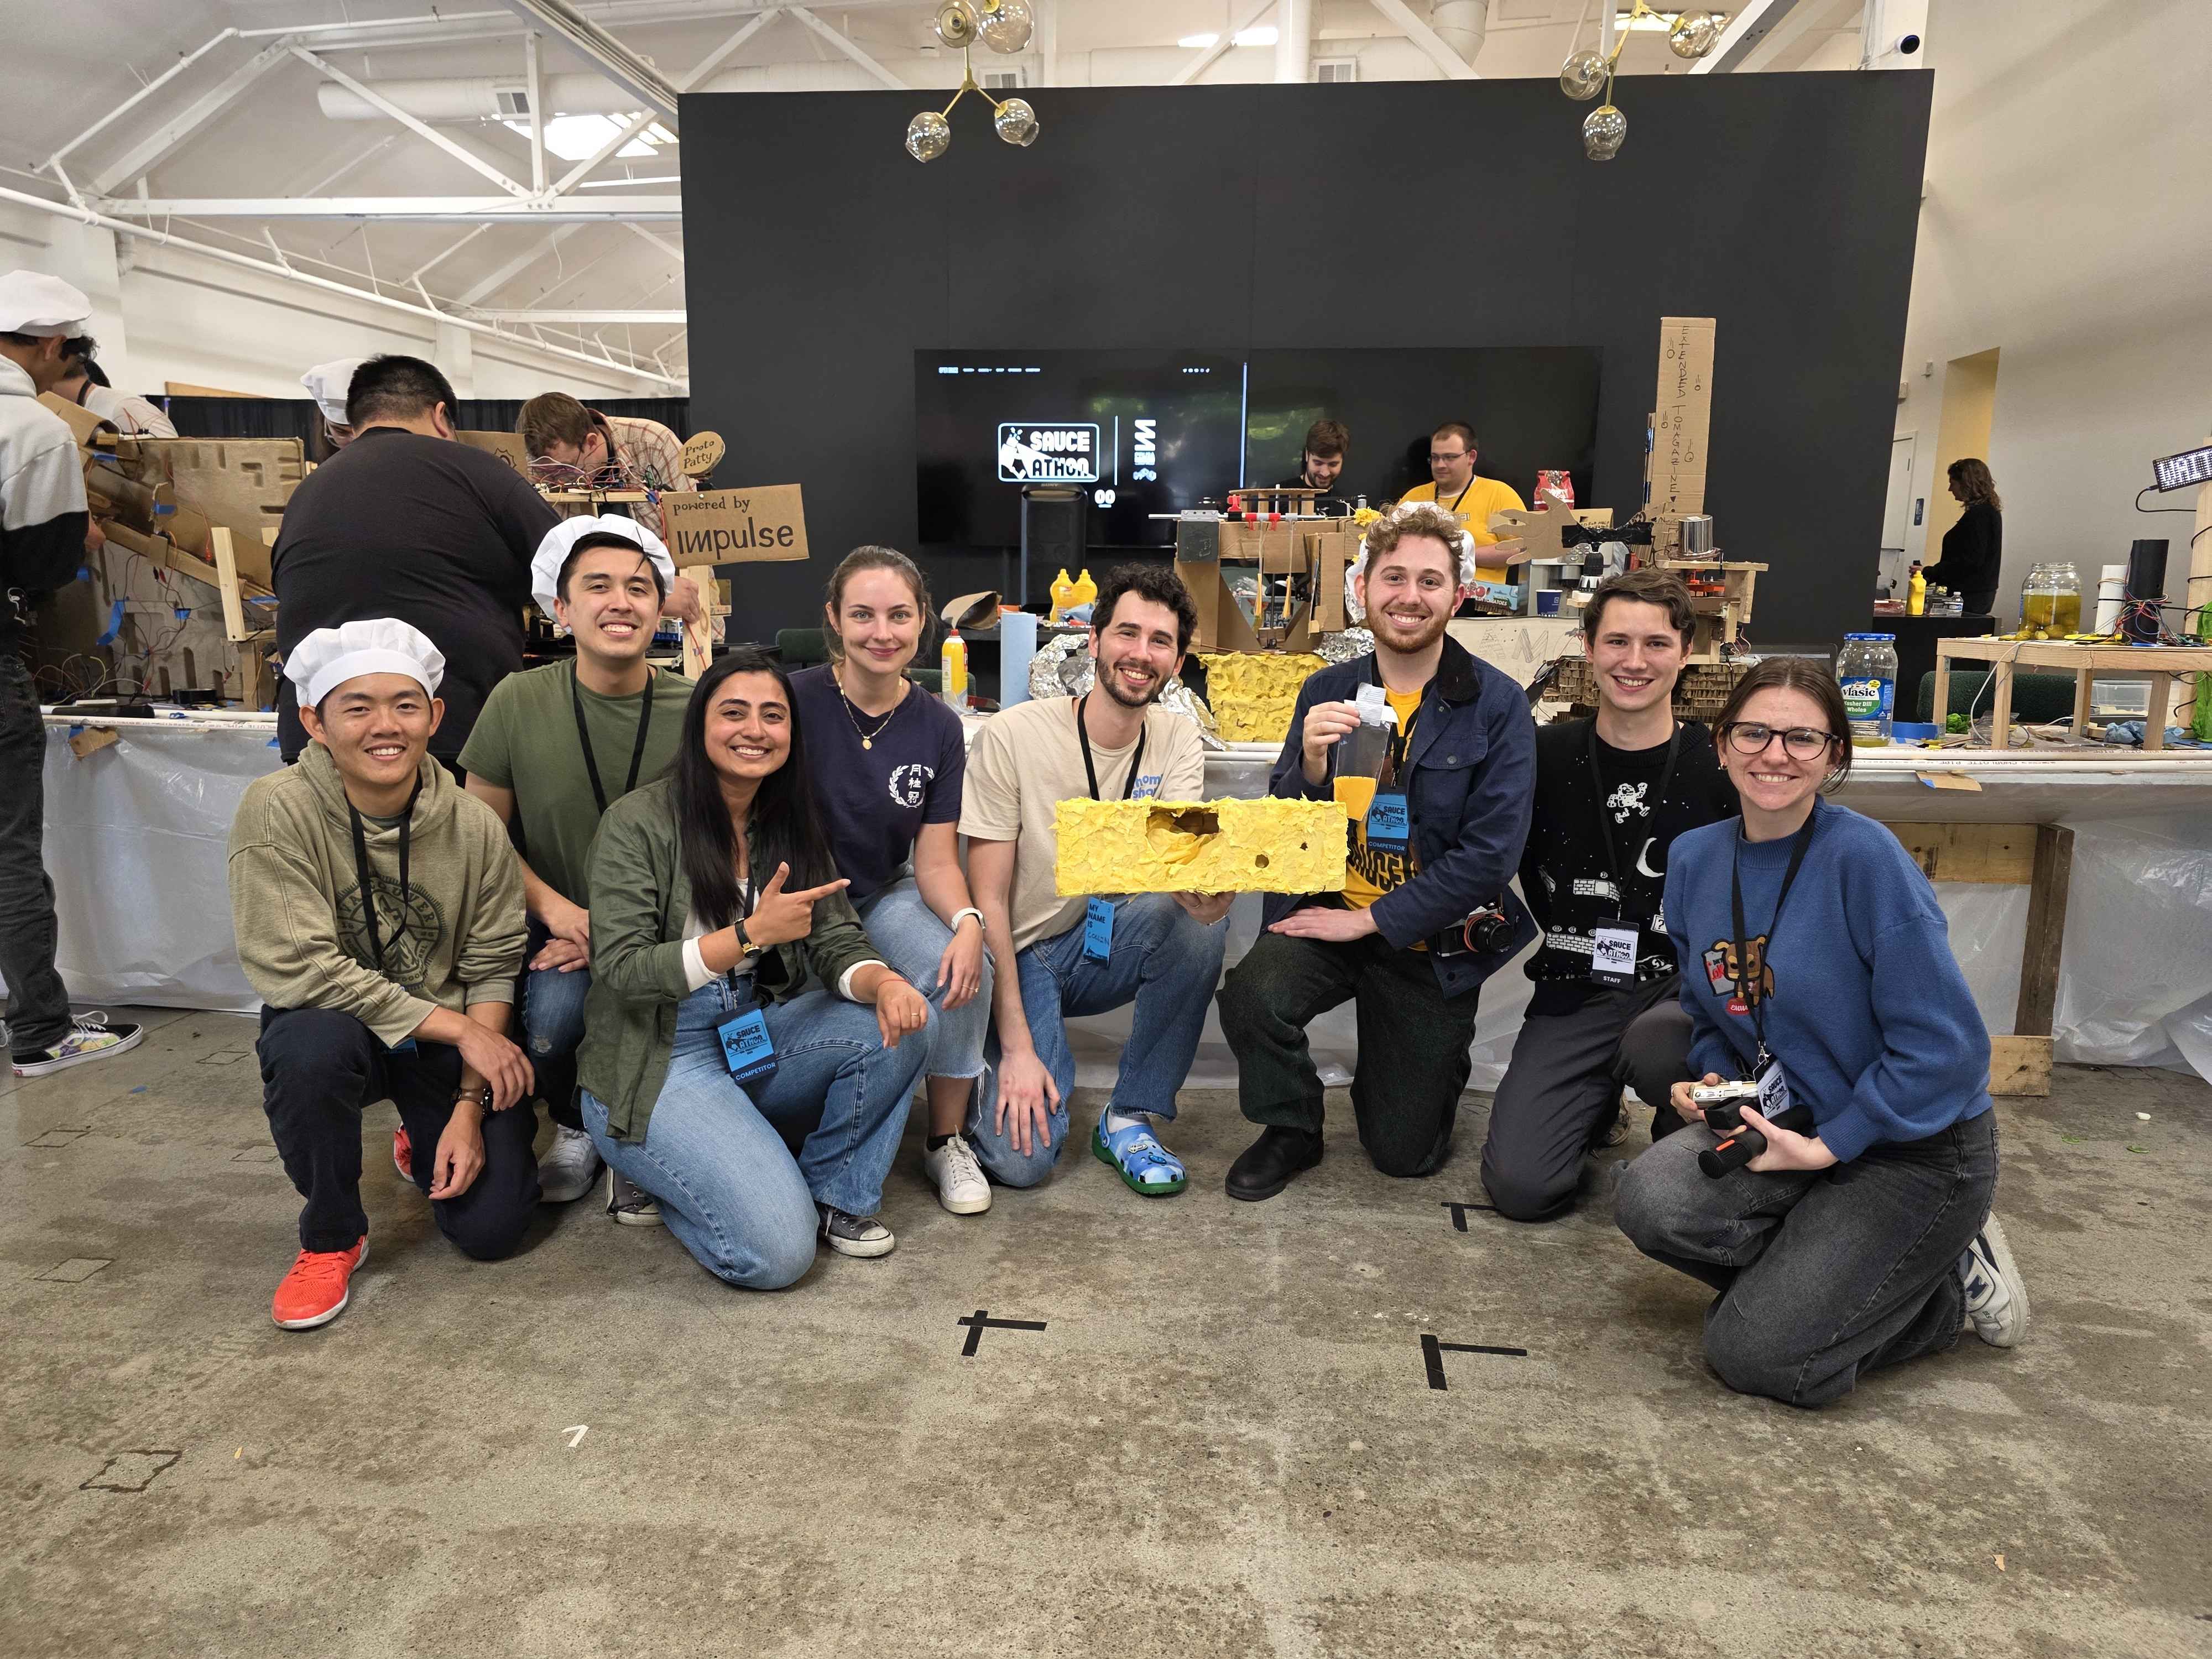
A 24-hour robotics hackathon where I collaborated with a mixed software and mechanical engineering team to build a robot designed to interact with both humans and other robots. A lesson in intersectional design and diverse perspectives.
View projectA data platform that makes it easy to incorporate privacy-safe practices into ML pipeline building — applying sanitization and vector embedding with industry best practices to protect personal information.
View projectAn ongoing research proposal: designing an accessible, private, and accurate robotic prosthetic that returns full user functionality and offers personalized collaboration during rehabilitation. Driven by distributed computing and ML.
Read proposal